wesc
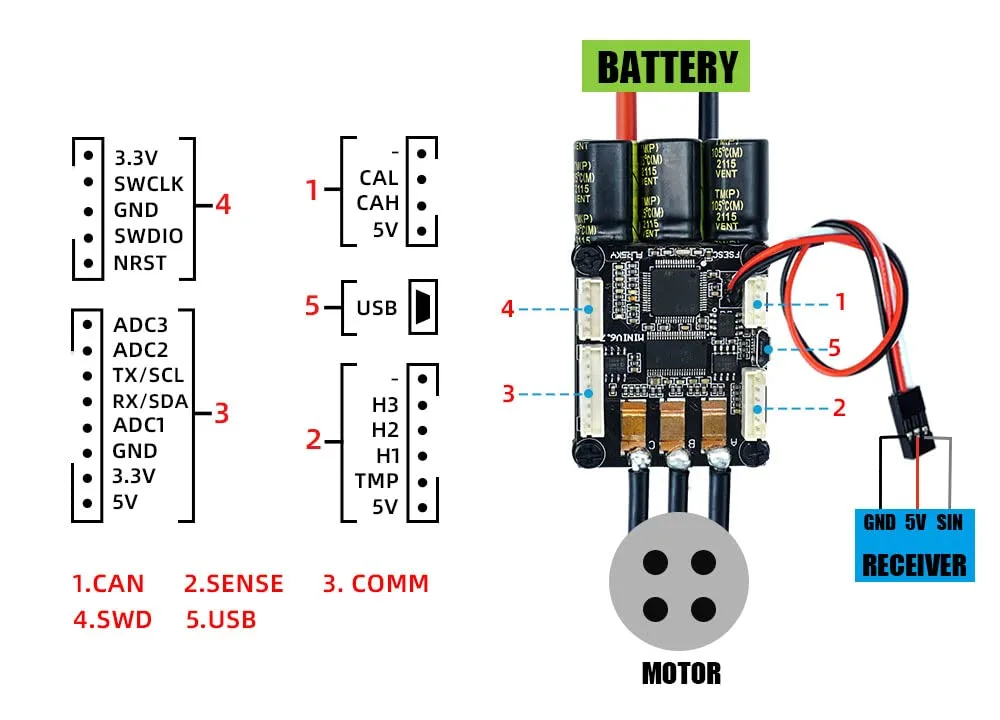
To make our self-driving car react faster, we stopped relying on the standard tools and wrote our own library to talk to its motor controller. Small, written in C, and open source soon.
Team
4 people
Context
Epitech RoboCar programme
Status
Done
Context
Built inside the RoboCar project (a UTAC challenge, one team per Epitech campus). Every driving decision of the car goes through this library, so its latency matters.
What was built
- Packet framing (start byte, length, payload, CRC-16, stop byte) and one encoder per command
- Telemetry decoding (temperatures, currents, RPM, voltage, fault codes) with strict framing and CRC checks
- Errors reported through errno, so the calling program can recover instead of crashing